Ptera Software
In early 2019, I became utterly obsessed with biological flight. However, after searching the library, online forums, and the brains of my professors, I wasn't able to find a fast, easy-to-use, and free tool for simulating flapping wings. So I decided to write one! Introducing my first open-source project: Ptera Software. I'm hoping it can spur the aerospace engineering community's interest and understanding of unsteady aerodynamics.
Daniobot
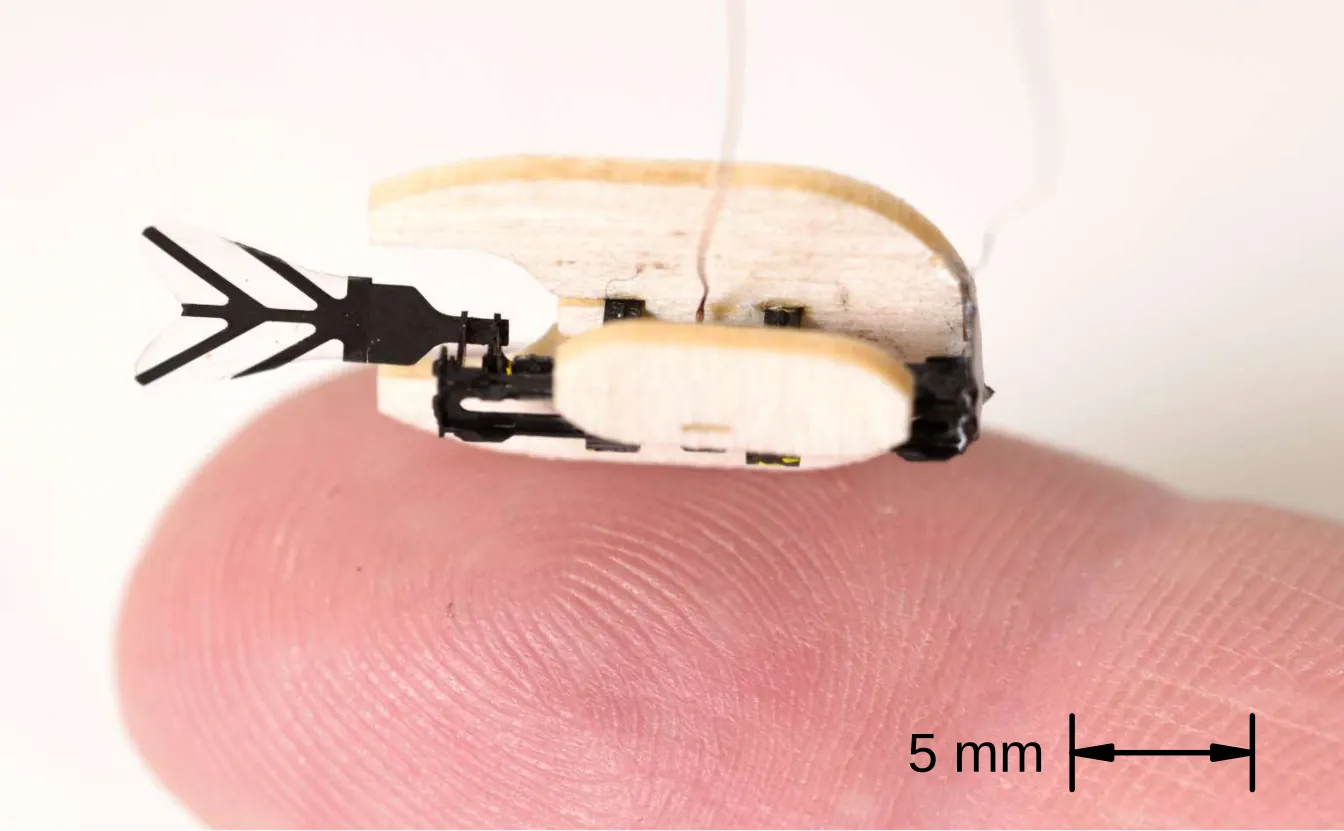
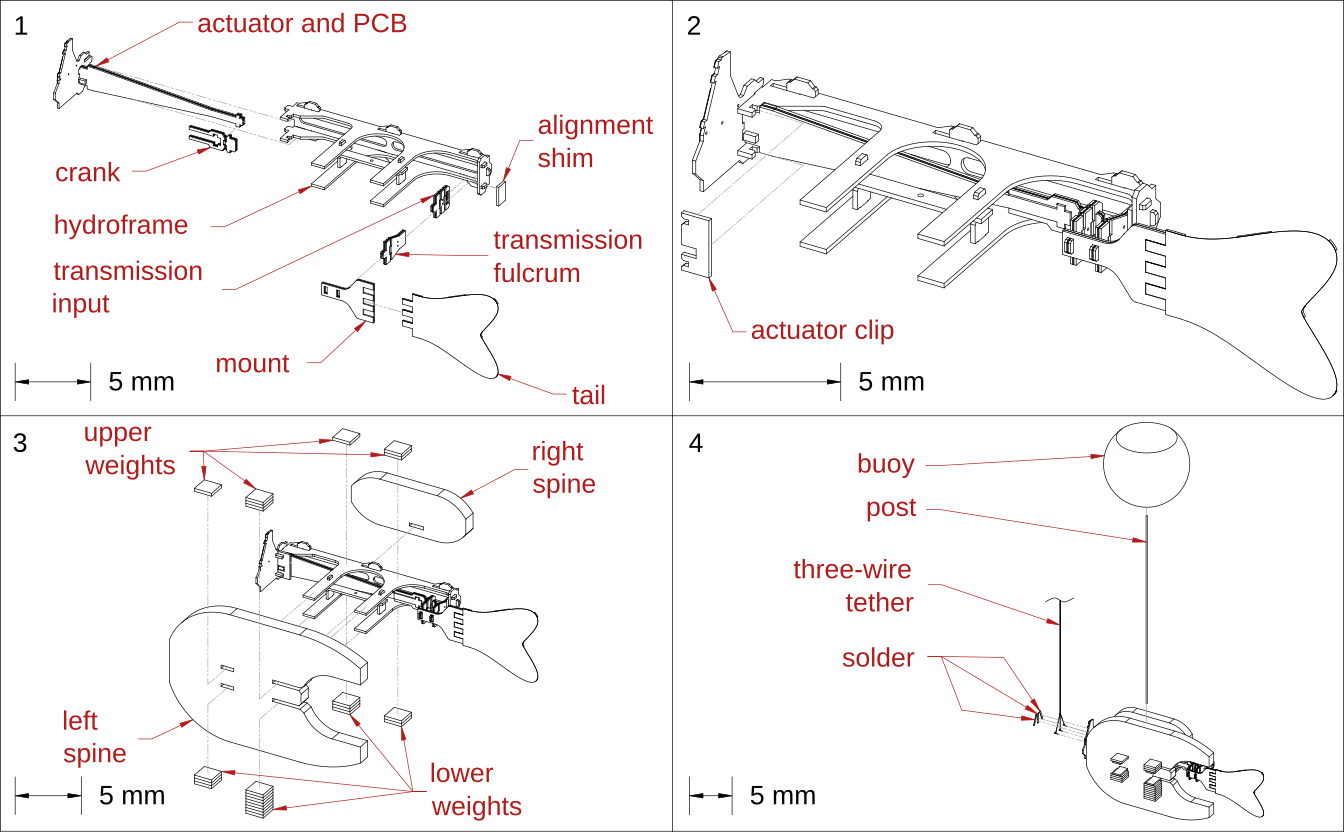
The Daniobot is a millimeter-scale robotic fish, named after the zebrafish, Danio rerio. With a 16.5 mm body and a total length of 23.8 mm, it is, to the best of my knowledge, the smallest fish-inspired robot propelled by onboard actuators (at the time of publication). A single piezoelectric bender drives its rigid tail through a flexure-based transmission, pushing the 0.472 g robot to top speeds of 2.84 body lengths per second. Its low 175 V drive voltage is a step toward a power-autonomous, untethered robotic fish.